

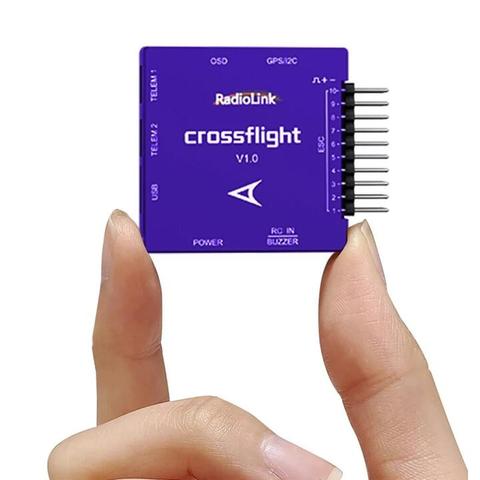
Radiolink Crossflight Flight Controller 2-12S 10 PWM FC wih OSD Modulefor FPV Racing Drone RC Car Boat
Price $93.05
At Bang Good In stock
Same price since 17 Nov
Tracking since 22 Oct
We may earn a commission at no cost to you. How it works
Price history
Tracking since 22 Oct · 27 days
- Now
- $93.05
- Lowest
- $89.33
- Highest
- $93.05
Latest price changes
- up↑1% yesterday $93.05
- up↑1% 3 days ago $92.09
- up↑1% 4 days ago $91.62
- 5 days ago $91.12
- 6 days ago $91.52
About this product
- Category
- Toys & Games > Toys > Flying Toys > Drones
The Crossflight FC is a flight controller designed for various types of aircraft and vehicles, including 3–8 axis multirotors, airplanes, helicopters, cars, and boats. It features an integrated OSD module and software-based vibration damping to ensure stable flight and accurate sensor data.
Key features
- Vibration damping by software for improved altitude hold and stability
- Integrated OSD module for real-time graphical display of flight information
- 10 channels PWM output
- Support for Neopix Led and Gripper Function
- RTK support
- Mini size as F4
Specifications
- Connector: JST GH1 25 Connector
- PWM Output: 10 PWM Output
- Mavlink UART: 2 without CTSRTS
- USB Port: 1 Type C
- GPS UART I2C Port: 1
- RC In Signal Input: PPM SBUS
- RSSI Output: Do not support
- OSD Module: OSD Module Integrated
- ESC Protocol: PWM
- DSHOT Protocol: Do not support
- ONESHOT Protocol: Do not support
- Neopix Led: Support
- Gripper Function: Support
- RTK Support: Support
- USB Voltage: 5V±0 3V
- Servo Voltage: Not applicable
- Operating Temperature: 40 80℃
- Adaptable Models: 3 8 copter Airplane Helicopter Car Boat
- Dimention: 39 7 39 7 13mm 1 56 1 56 0 51
- Weight: 16 5g 0 58oz 54g 1 9oz when all the connect wires included
- Processor: HC32F4A0PITB
- Gyro: ICM42670
- Compass: VCM5883
- Barometer: LPS22HBF
- FRAM: Without FRAM use the internal flash to store parameters
- Waypoints: 2617 waypoints for multi copters and 2623 waypoints for airplanes
- Power Module Input Voltage: 2 12S
- Power Module Input Current: 90A
- Power Module Output Voltage: 5 1V
- Power Module Output Current BEC: 2 5A
- Power Module Input Current connect to one ESC only: 20A
Tidied up with AI from the store's description