

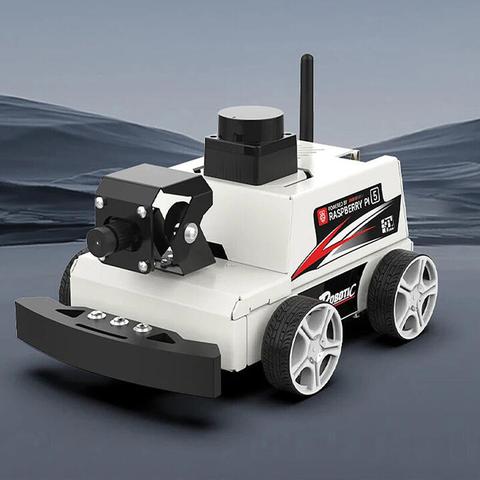
Yahboom ROS2 Robot Car Kit with TOF Lidar Support AI Visual Recognition SLAM Mapping Navigation Electronic Education Set
Price $367.66
Sold by Bang Good In stock
Same price since 15 Nov
Tracking since 22 Oct
We may earn a commission at no cost to you. How it works
Price history
Tracking since 22 Oct · 25 days
- Now
- $367.66
- Lowest
- $356.66
- Highest
- $367.66
Latest price changes
- up↑1% yesterday $367.66
- up↑1% 2 days ago $365.77
- 3 days ago $363.78
- 4 days ago $365.37
- up↑1% 6 days ago $366.33
About this product
- Store
- Bang Good
- Category
- Toys & Games > Toys > Educational Toys > Coding & Robotics Learning Toys
- SKU
- 2017760
This MicroROS Pi5 ROS2 car is a robot expansion board developed based on the Raspberry Pi 5 for tasks such as robot motion control, AI visual interaction, and SLAM mapping navigation. It supports the ROS2 HUMBLE development environment and Python3 programming using OpenCV and MediaPipe algorithms.
Key features
- MicroROS robot expansion board with ESP32 co-processor
- 4PCS 310 encoder motors with rubber tires
- 7.4V 2000mAh rechargeable battery
- MS200 lidar and 2MP camera
- 2DOF gimbal and aluminum alloy frame
- Supports mobile APP, wireless controller, and computer keyboard control
- Includes detailed tutorial materials, installation videos, and technical support
Specifications
- Main control board: Raspberry Pi 5
- System version: RaspberryPiOs ROS2 operating system version Humble
- Agent connection method: Supports WiFi UDP and serial mode (defaults to serial mode)
- Programming language: Python, C language
- Input: 6 axis IMU, MS200 lidar, motor with encoder, custom buttons, custom GPIO, 2 camera
- Output: Buzzer, 310 motor interface 4, servo PTZ
- Servo solution: YB SG90 9G digital servo
- Camera solution: 2MP 120° High frame rate camera
- Motor solution: 310 metal motor with encoder 4
- Motor speed: 450 10rpm
- Motor torque: 4kg cm
- Wheel type: Rubber tires size 48 21 5mm
- Power plan: 7.4V 2000mAh 2S lithium battery
- Battery life: 2 hours
Package contents
- Not includes
Tidied up with AI from the store's description